Abstract
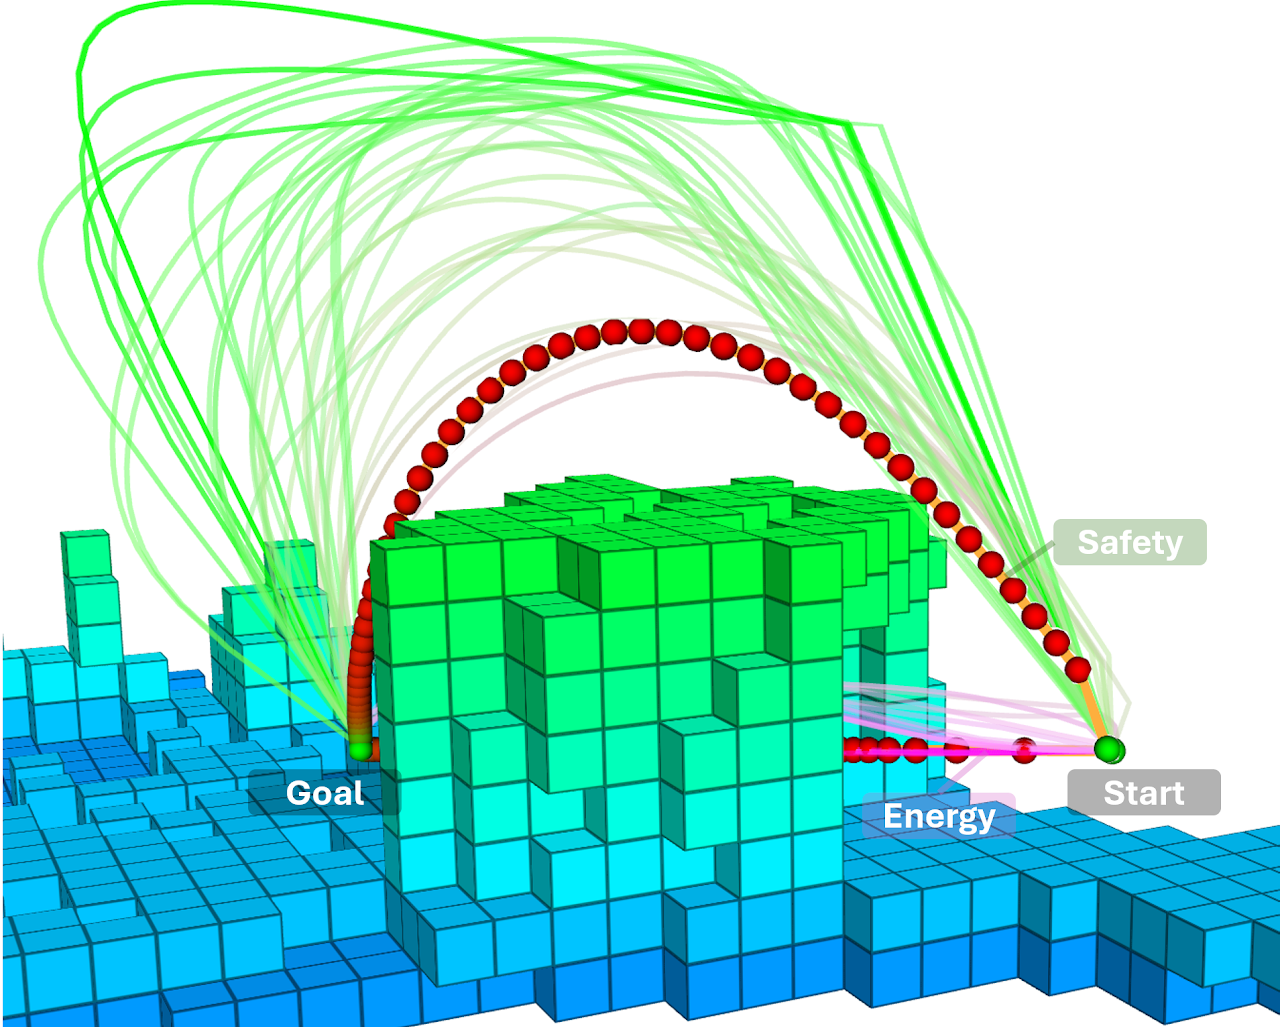
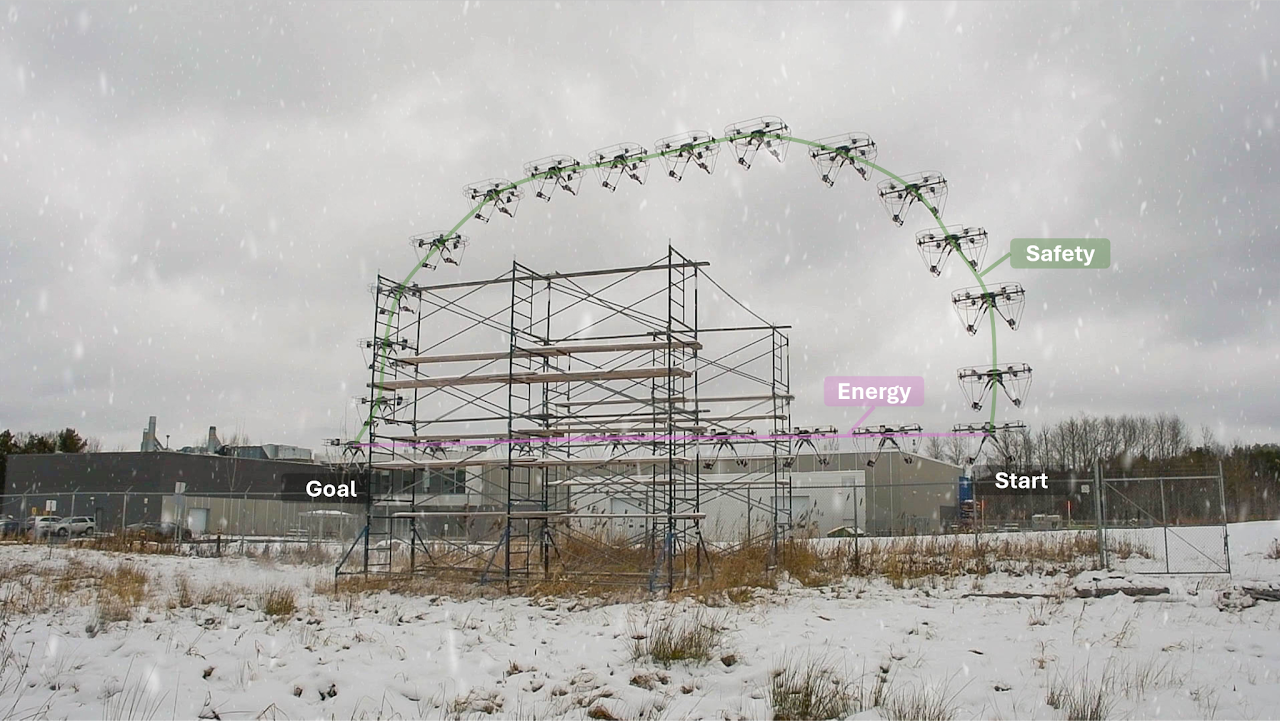
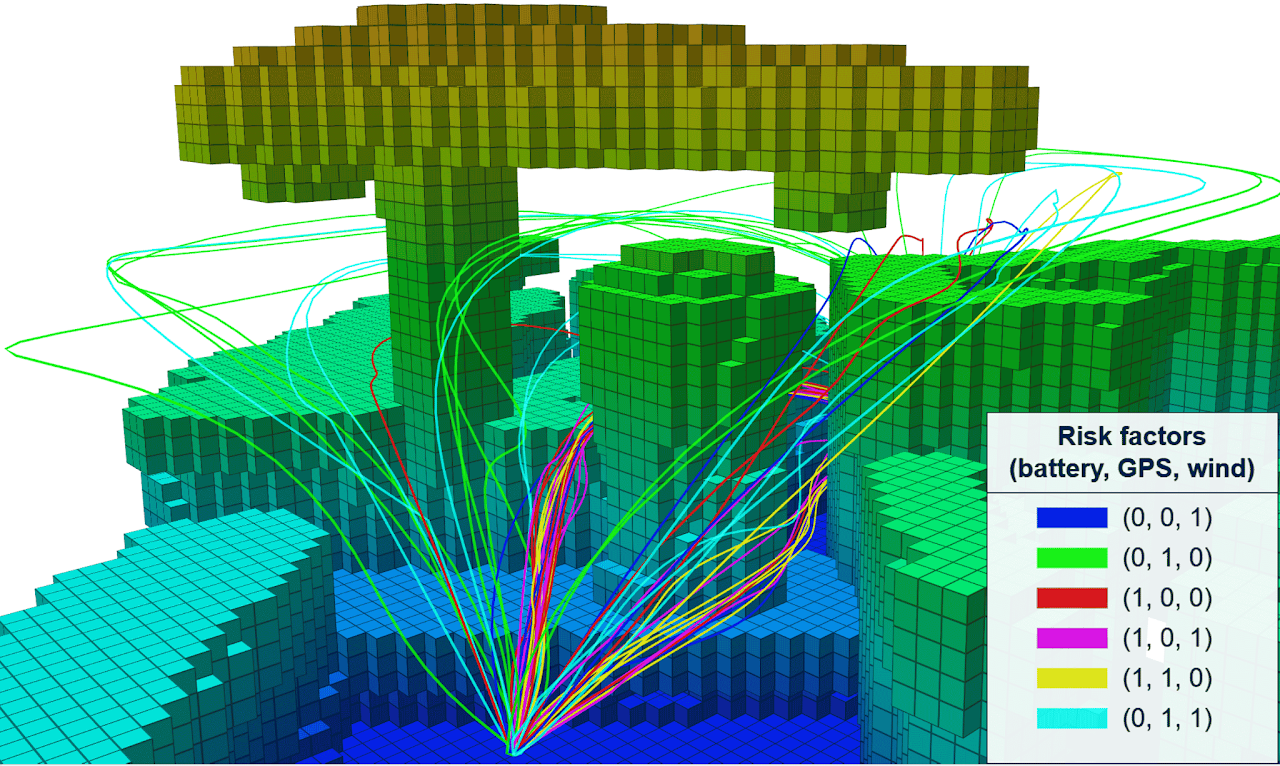
Autonomous robotic inspection missions require balancing multiple conflicting objectives while navigating near costly obstacles. Current multi-objective path planning (MOPP) methods struggle to adapt to evolving risks like localization errors, weather, battery state, and communication issues. This letter presents an Adaptive Risk-aware and Energy-efficient NAvigation (ARENA) MOPP approach for UAVs in complex 3D environments. Our method enables online trajectory adaptation by optimizing safety, time, and energy using 4D NURBS representation and a genetic-based algorithm to generate the Pareto front. A novel risk-aware voting algorithm ensures adaptivity. Simulations and real-world tests demonstrate the planner’s ability to produce diverse, optimized trajectories covering 95% or more of the range defined by single-objective benchmarks and its ability to estimate power consumption with a mean error representing 14% of the full power range. The ARENA framework enhances UAV autonomy and reliability in critical, evolving 3D missions.
BibTeX
@article{poissant2027arena,
  author = {Poissant, David-Alexandre and Desbiens, Alexis Lussier and Ferland, Fran{\c{c}}ois and Petit, Louis},
  title = {ARENA: Adaptive Risk-aware Navigation for Autonomous Aerial Inspection},
  journal = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2027},
  note = {Under review},
  url = {https://arxiv.org/abs/2502.19401}
}