At the SAFiR Lab, we believe that reproducible research accelerates scientific progress. Whenever possible, we release the software, datasets, and tools developed in our research to support the robotics community and facilitate the adoption, validation, and extension of our work.
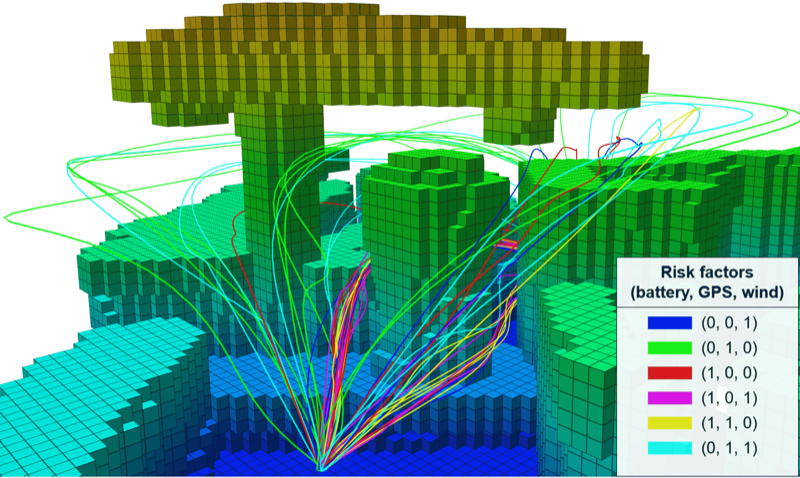
ARENA: Adaptive Risk-aware Navigation for Autonomous Aerial Inspection
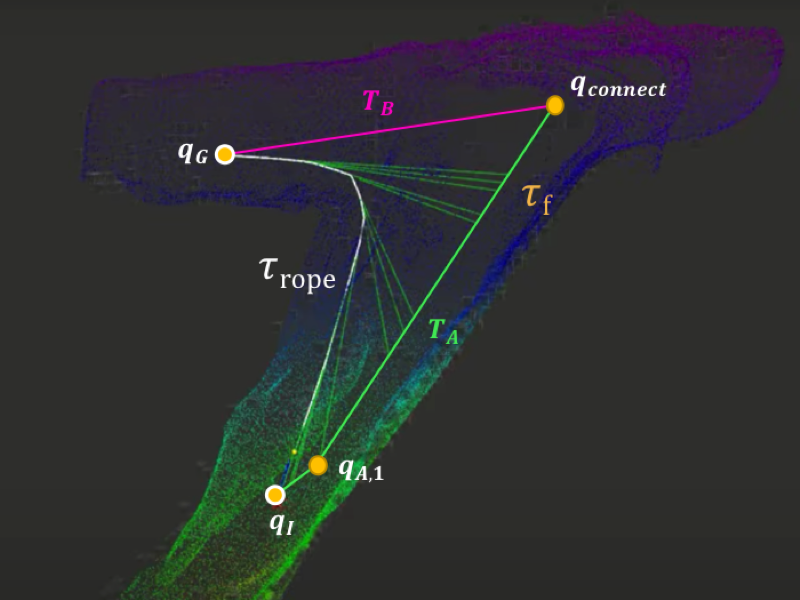
RRT-Rope: A deterministic shortening approach for fast near-optimal path planning
To use it in robotics applications or other planning pipelines, the RRT-Rope algorithm is available directly in the Open Motion Planning Library (OMPL). It is implemented as the ropeShortcutPath function, documented here. Below is a minimal example of how to use it:
#include <ompl/geometric/planners/rrt/RRTConnect.h>
#include <ompl/geometric/PathGeometric.h>

// Assuming 'planner' is an instance of ompl::geometric::RRTConnect
getPlanner()->as<ompl::geometric::RRTConnect>()->setProblemDefinition(getProblemDefinition());

// Attempt to solve the problem within a given planning time
ompl::base::PlannerStatus solved = planner_->solve(1.0);

if (solved) {
    // Get the solution path
    auto *sln = static_cast<ompl::geometric::PathGeometric*>(getProblemDefinition()->getSolutionPath().get());

    // Perform Rope Shortcut
    getPathSimplifier()->ropeShortcutPath(*sln);
}