2027
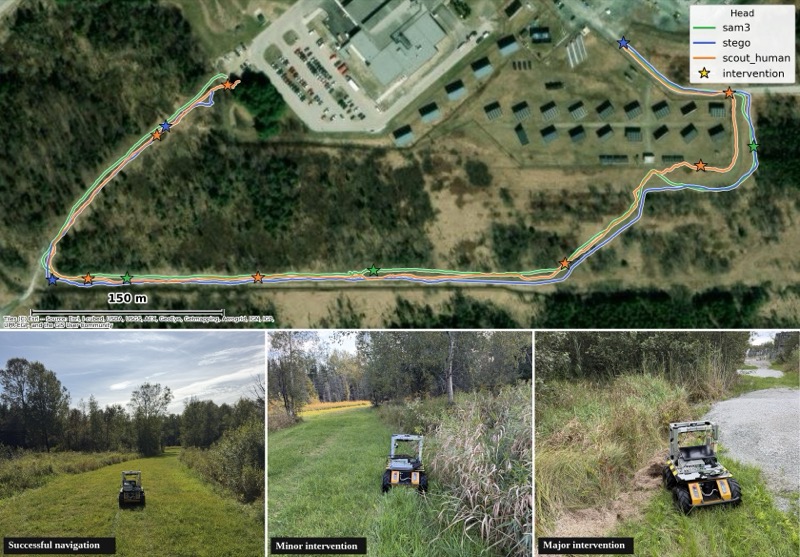
FLINT: Fast Lightweight Inference for Traversability.
(under review) 2027 IEEE International Conference on Robotics and Automation (ICRA)
@inproceedings{bonilla2027flint,
  author = {Bonilla, William and Boisvert, Maxime and Poissant, David-Alexandre and Meger, David and Petit, Louis},
  title = {FLINT: Fast Lightweight Inference for Traversability},
  booktitle = {2027 IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2027},
  note = {Under review},
  url = {https://arxiv.org/abs/2609.26857}
}
Bonilla, W., Boisvert, M., Poissant, D., Meger, D. & Petit, L. FLINT: Fast Lightweight Inference for Traversability. (under review) 2027 IEEE International Conference on Robotics and Automation (ICRA), 2027.
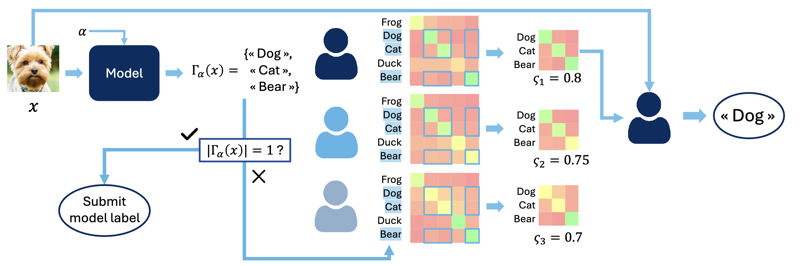
No Need for Learning to Defer? A Training Free Deferral Framework to Multiple Experts through Conformal Prediction.
(under review) 2027 AAAI Conference on Artificial Intelligence
@inproceedings{bary2027deferral,
  author = {Bary, Tim and Macq, Beno{\^\i}t and Petit, Louis},
  title = {No Need for Learning to Defer? A Training Free Deferral Framework to Multiple Experts through Conformal Prediction},
  booktitle = {2027 AAAI Conference on Artificial Intelligence},
  year = {2027},
  note = {Under review},
  url = {https://arxiv.org/abs/2509.12573}
}
Bary, T., Macq, B. & Petit, L. No Need for Learning to Defer? A Training Free Deferral Framework to Multiple Experts through Conformal Prediction. (under review) 2027 AAAI Conference on Artificial Intelligence, 2027.
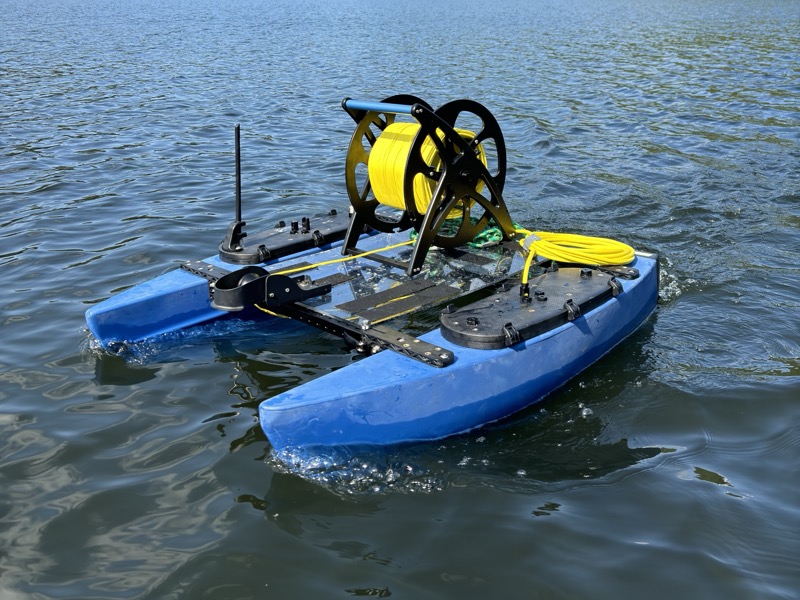
Learning to Sample: A Reinforcement Learning Framework for Aquatic Environmental Mapping.
(under review) IEEE Robotics and Automation Letters (RA-L)
@article{alhosh2027sample,
  author = {Alhosh, Julie and Tremblay, Jean-Fran{\c{c}}ois and Wiltzer, Harley and Bodzay, Ellen and Petit, Louis and Meger, David},
  title = {Learning to Sample: A Reinforcement Learning Framework for Aquatic Environmental Mapping},
  journal = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2027},
  note = {Under review}
}
Alhosh, J., Tremblay, J., Wiltzer, H., Bodzay, E., Petit, L. & Meger, D. Learning to Sample: A Reinforcement Learning Framework for Aquatic Environmental Mapping. (under review) IEEE Robotics and Automation Letters (RA-L), 2027.
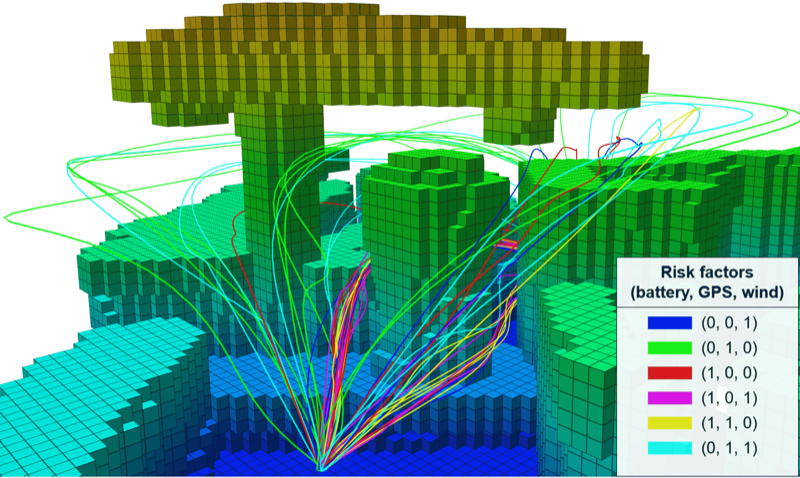
ARENA: Adaptive Risk-aware Navigation for Autonomous Aerial Inspection.
(under review) IEEE Robotics and Automation Letters (RA-L)
@article{poissant2027arena,
  author = {Poissant, David-Alexandre and Desbiens, Alexis Lussier and Ferland, Fran{\c{c}}ois and Petit, Louis},
  title = {ARENA: Adaptive Risk-aware Navigation for Autonomous Aerial Inspection},
  journal = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2027},
  note = {Under review},
  url = {https://arxiv.org/abs/2502.19401}
}
Poissant, D., Desbiens, A.L., Ferland, F. & Petit, L. ARENA: Adaptive Risk-aware Navigation for Autonomous Aerial Inspection. (under review) IEEE Robotics and Automation Letters (RA-L), 2027.
2026
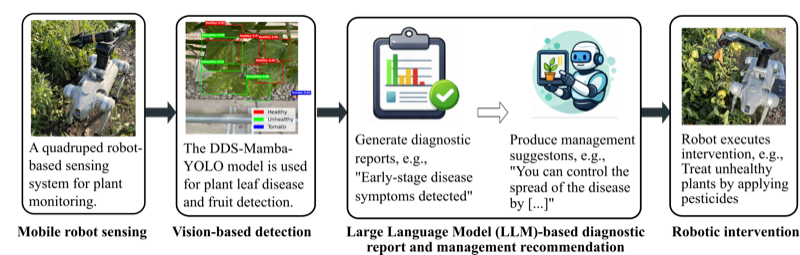
DDS-Mamba-YOLO: Improved adaptive state-space modeling for tomato fruit and leaf disease detection.
Smart Agricultural Technology
@article{zhu2026dds,
  author = {Zhu, Jiajun and Bary, Tim and Petit, Louis and Sun, Shangpeng},
  title = {DDS-Mamba-YOLO: Improved adaptive state-space modeling for tomato fruit and leaf disease detection},
  journal = {Smart Agricultural Technology},
  year = {2026},
  url = {https://www.sciencedirect.com/science/article/pii/S2772375526006490}
}
Zhu, J., Bary, T., Petit, L. & Sun, S. DDS-Mamba-YOLO: Improved adaptive state-space modeling for tomato fruit and leaf disease detection. Smart Agricultural Technology, 2026.
2025
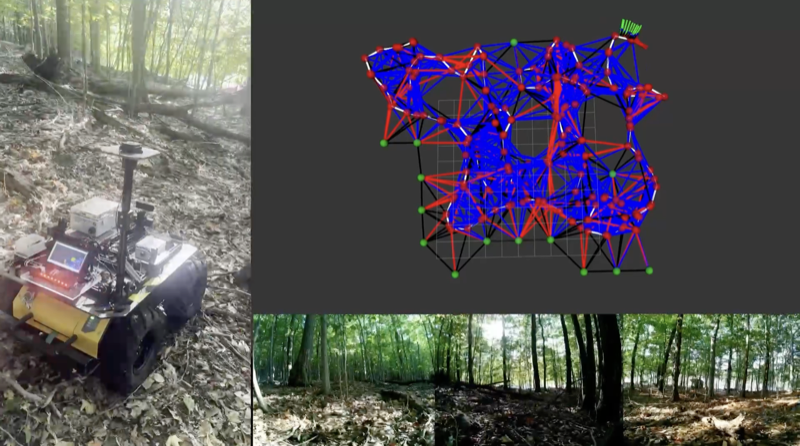
Topological mapping for traversability-aware long-range navigation in off-road terrain.
2025 IEEE International Conference on Robotics and Automation (ICRA)
@inproceedings{tremblay2025topological,
  author = {Tremblay, Jean-Fran{\c{c}}ois and Alhosh, Julie and Petit, Louis and Lotfi, Faraz and Landauro, Lara and Meger, David},
  title = {Topological mapping for traversability-aware long-range navigation in off-road terrain},
  booktitle = {2025 IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2025},
  url = {https://arxiv.org/abs/2410.01925}
}
Tremblay, J., Alhosh, J., Petit, L., Lotfi, F., Landauro, L. & Meger, D. Topological mapping for traversability-aware long-range navigation in off-road terrain. 2025 IEEE International Conference on Robotics and Automation (ICRA), 2025.
2024
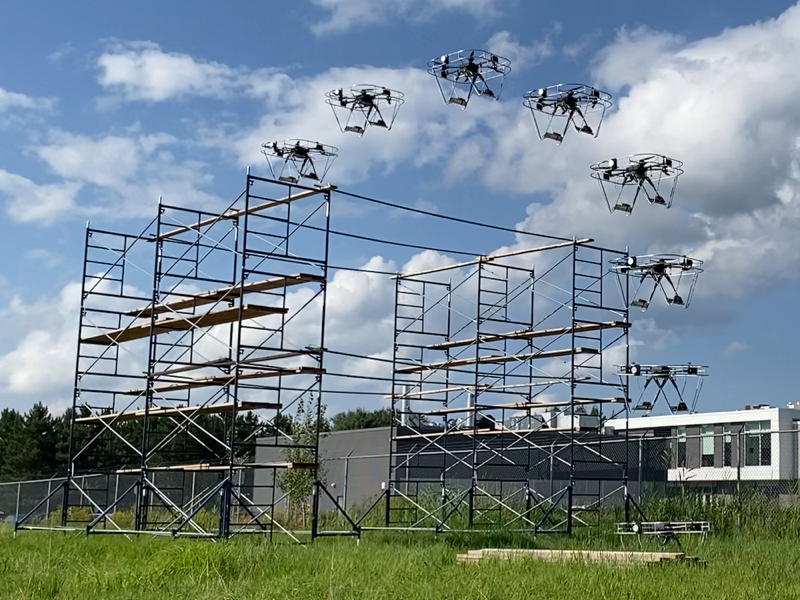
MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV.
2024 IEEE International Conference on Robotics and Automation (ICRA)
@inproceedings{petit2024moar,
  author = {Petit, Louis and Desbiens, Alexis Lussier},
  title = {MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV},
  booktitle = {2024 IEEE International Conference on Robotics and Automation (ICRA)},
  year = {2024},
  url = {https://arxiv.org/abs/2606.30575}
}
Petit, L. & Desbiens, A.L. MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV. 2024 IEEE International Conference on Robotics and Automation (ICRA), 2024.
2023
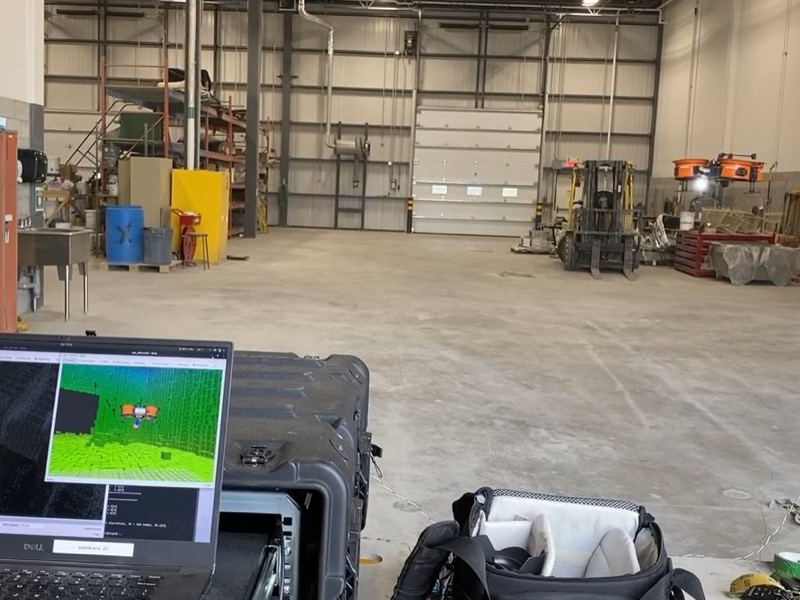
Enabling Efficient Autonomous Exploration of Unknown Underground Mining Stopes using a Tethered Aerial Robot
PhD thesis, Université de Sherbrooke
@phdthesis{petit2023phd,
  author = {Petit, Louis},
  title = {Enabling Efficient Autonomous Exploration of Unknown Underground Mining Stopes using a Tethered Aerial Robot},
  school = {Universit{\'e} de Sherbrooke},
  year = {2023},
  url = {https://savoirs.usherbrooke.ca/handle/11143/20205}
}
Petit, L. Enabling Efficient Autonomous Exploration of Unknown Underground Mining Stopes using a Tethered Aerial Robot PhD thesis, Université de Sherbrooke, 2023.
2022
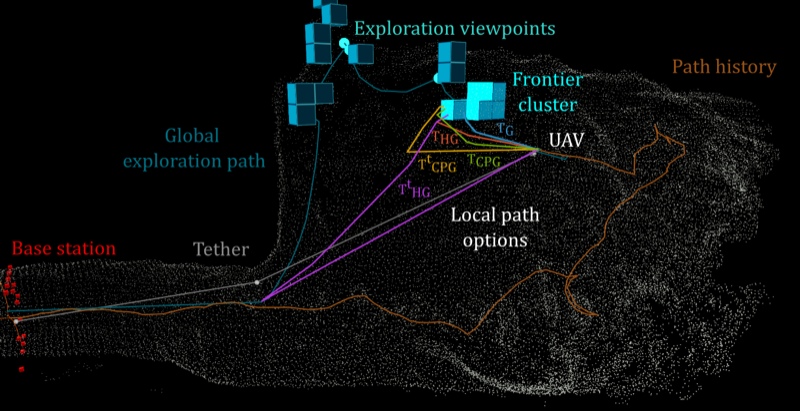
TAPE: Tether-Aware Path Planning for Autonomous Exploration of Unknown 3D Cavities Using a Tangle-Compatible Tethered Aerial Robot.
IEEE Robotics and Automation Letters (RA-L)
@article{petit2022tape,
  author = {Petit, Louis and Desbiens, Alexis Lussier},
  title = {TAPE: Tether-Aware Path Planning for Autonomous Exploration of Unknown 3D Cavities Using a Tangle-Compatible Tethered Aerial Robot},
  journal = {IEEE Robotics and Automation Letters (RA-L)},
  year = {2022},
  url = {https://arxiv.org/abs/2606.30817}
}
Petit, L. & Desbiens, A.L. TAPE: Tether-Aware Path Planning for Autonomous Exploration of Unknown 3D Cavities Using a Tangle-Compatible Tethered Aerial Robot. IEEE Robotics and Automation Letters (RA-L), 2022.
2021
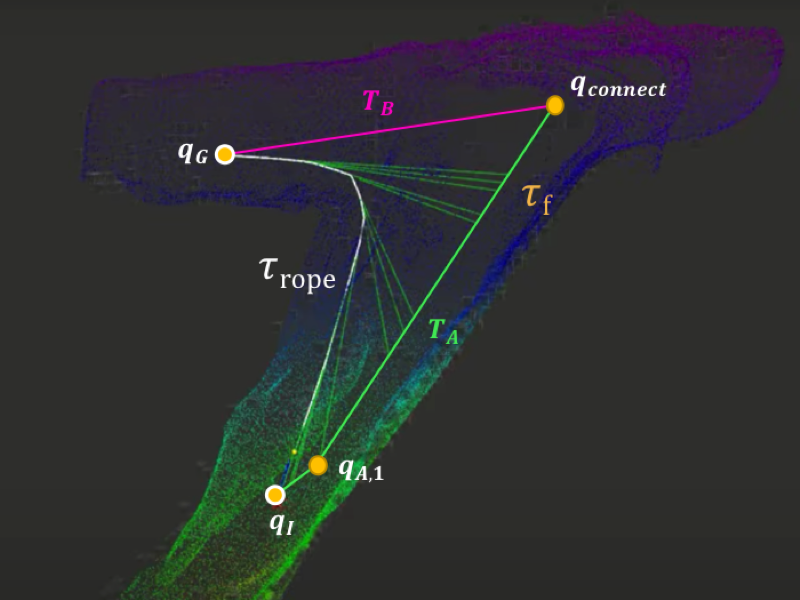
RRT-Rope: A Deterministic Shortening Approach for Fast Near-optimal Path Planning in Large-Scale Uncluttered 3D Environments.
2021 IEEE International Conference on Systems, Man, and Cybernetics (SMC)
Best Student Paper Award and Finalist for the Best Paper Award
@inproceedings{petit2021rrtrope,
  author = {Petit, Louis and Desbiens, Alexis Lussier},
  title = {RRT-Rope: A Deterministic Shortening Approach for Fast Near-optimal Path Planning in Large-Scale Uncluttered 3D Environments},
  booktitle = {2021 IEEE International Conference on Systems, Man, and Cybernetics (SMC)},
  year = {2021},
  url = {https://arxiv.org/abs/2606.31948}
}
Petit, L. & Desbiens, A.L. RRT-Rope: A Deterministic Shortening Approach for Fast Near-optimal Path Planning in Large-Scale Uncluttered 3D Environments. 2021 IEEE International Conference on Systems, Man, and Cybernetics (SMC), 2021.