Louis Petit
Professor
Research topics
- Autonomous aerial robots and UAV path planning
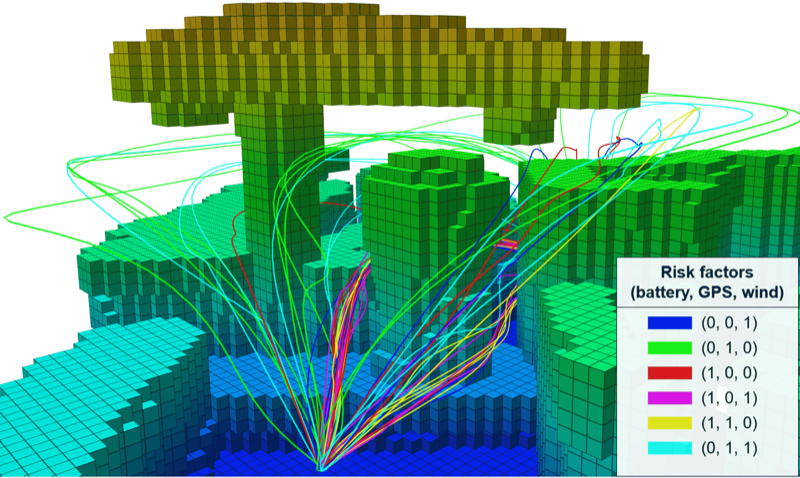
- Risk-aware and multi-objective navigation for infrastructure inspection
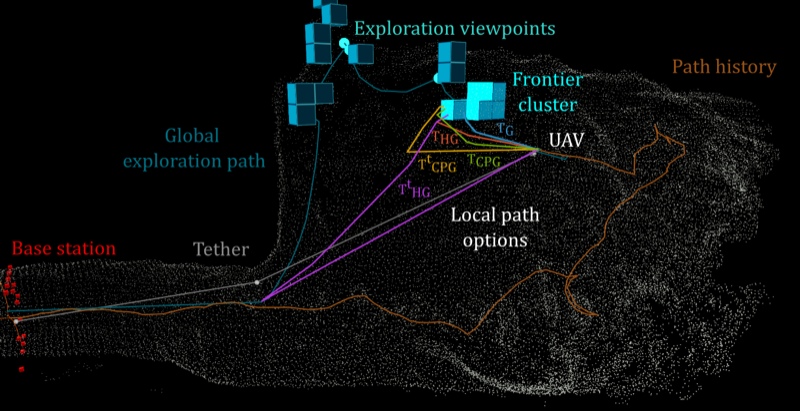
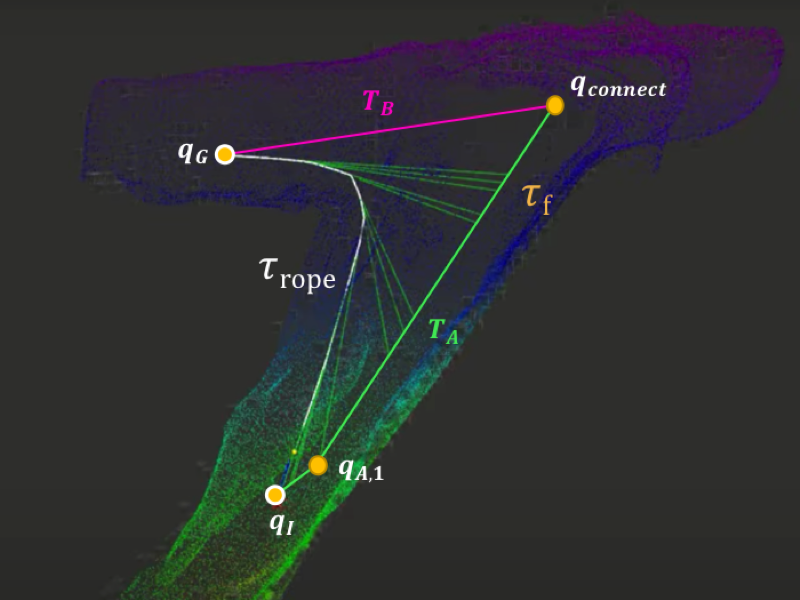
- Tethered aerial robots for exploring confined spaces such as mines and cavities
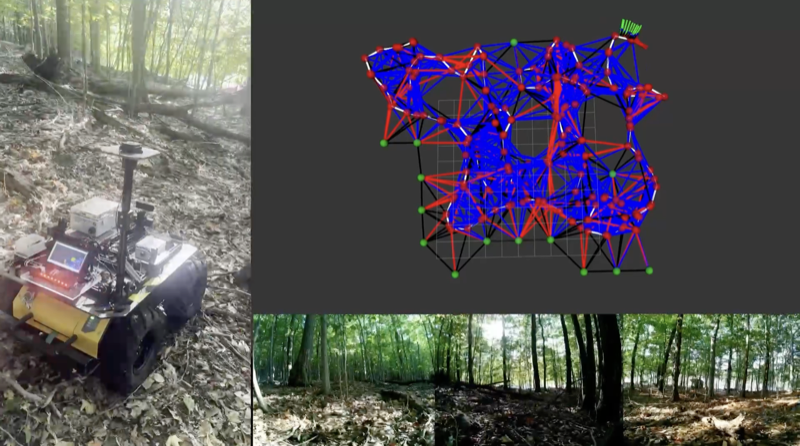
- Off-road traversability estimation and topological navigation
- Learning-based sampling and environmental mapping
- Human-AI decision-making
- Agriculture and environmental monitoring with computer vision
Publications
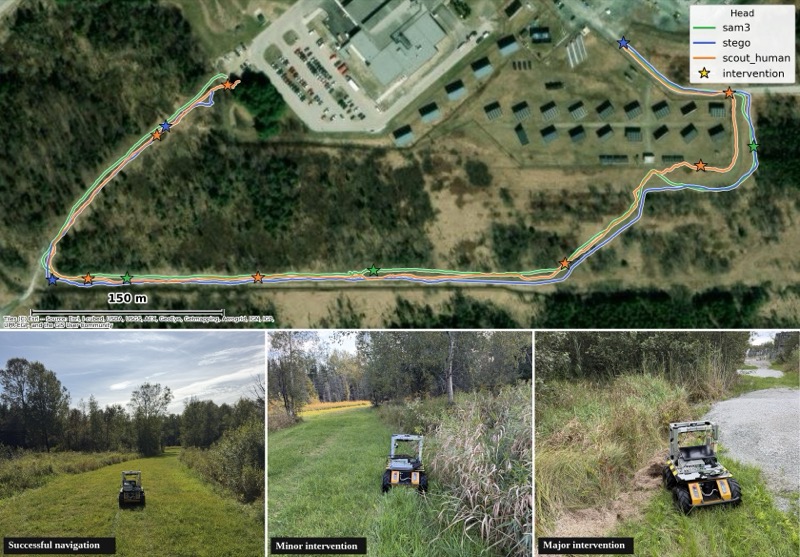
FLINT: Fast Lightweight Inference for Traversability.
(under review) 2027 IEEE International Conference on Robotics and Automation (ICRA) (2027)
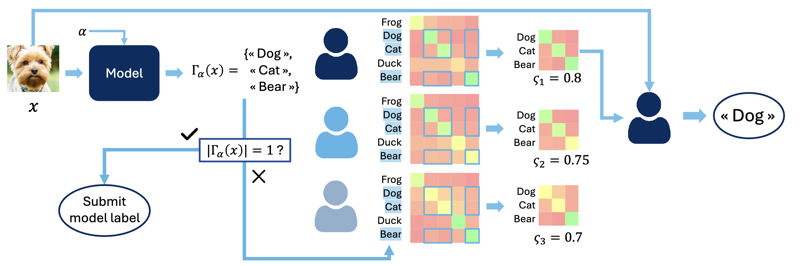
No Need for Learning to Defer? A Training Free Deferral Framework to Multiple Experts through Conformal Prediction.
(under review) 2027 AAAI Conference on Artificial Intelligence (2027)
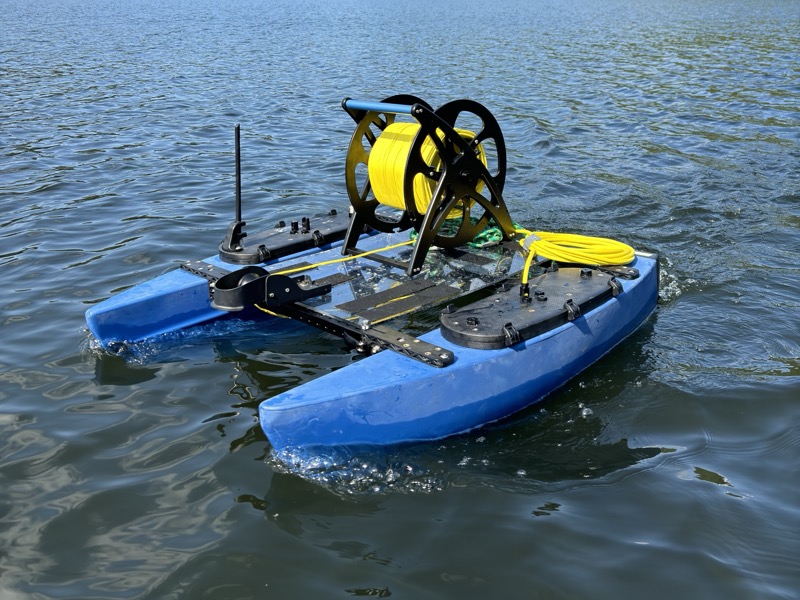
Learning to Sample: A Reinforcement Learning Framework for Aquatic Environmental Mapping.
(under review) IEEE Robotics and Automation Letters (RA-L) (2027)
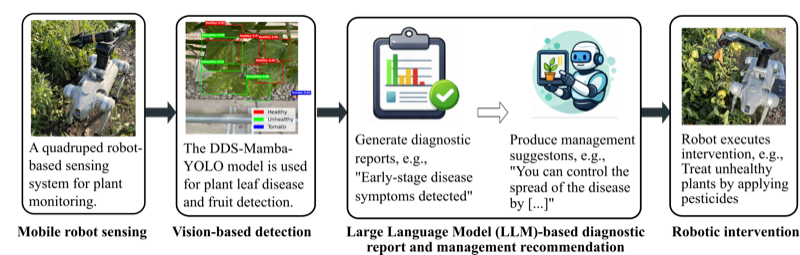
DDS-Mamba-YOLO: Improved adaptive state-space modeling for tomato fruit and leaf disease detection.
Smart Agricultural Technology (2026)
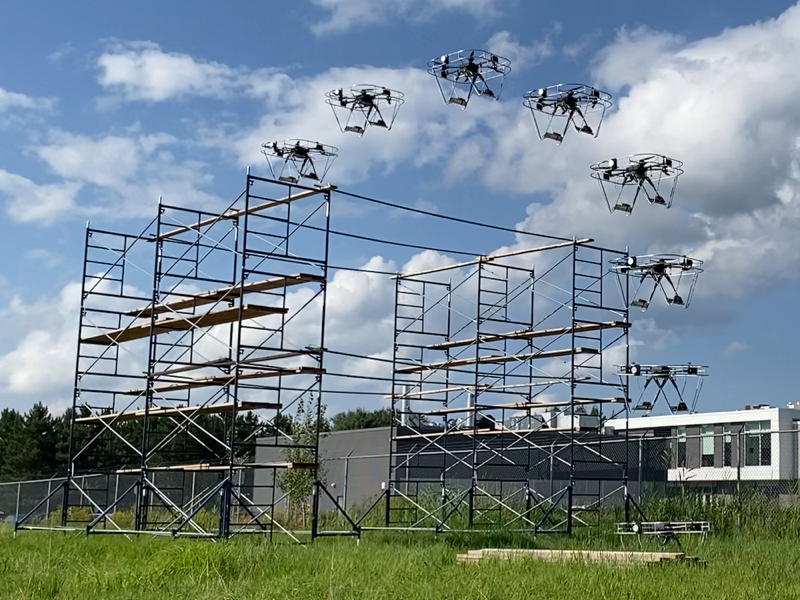
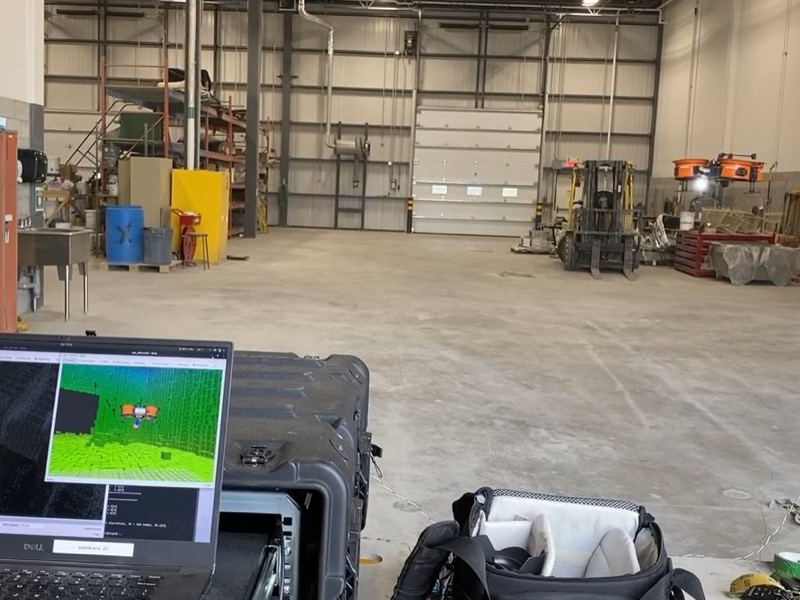
Enabling Efficient Autonomous Exploration of Unknown Underground Mining Stopes using a Tethered Aerial Robot
PhD thesis, Université de Sherbrooke (2023)